One cell of the Go1 map, three cameras: a clip is one draw from a stochastic system, so it is an illustration, and the numbers below rest on the runs.
01Proof
A safer policy. Measured, condition by condition.
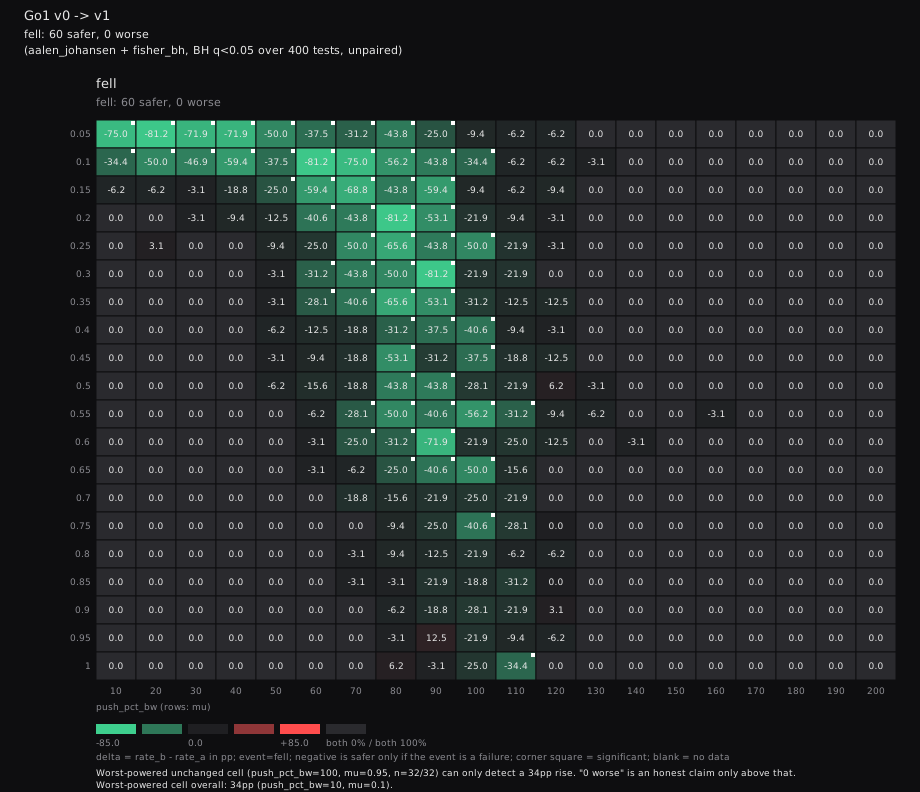
A simulated Unitree Go1 across 400 conditions of friction and push. The map showed two gaps its training had never covered; we retrained on those and ran both versions again.
60
conditions significantly safer
0
conditions significantly worse
340 showed no significant change. The least sensitive could not have detected a rise under 34 percentage points.
It calls (cfg, seed) -> Episode once per condition and seed, and keeps the seeds matched. Any simulator you call from Python works, on AWS, GCP, Azure, Your machine, Modal.
shell · poisson-prove
pip install poisson-provepoisson-prove init --example# 1. sweep the conditions, before the changepoisson-prove sweep --yes# 2. sweep again after it, on the same seedspoisson-prove sweep --yes \ --target poisson_prove.examples.mock_agent:rollout_patched \ --pair-with latest# 3. compare the pair into report.md, heatmap.svg, receipt.htmlpoisson-prove report --event violated --x tool_fail_rate --y task_id# in CI: exit 4 if any condition came back significantly worsepoisson-prove check --event violated --fail-on worse